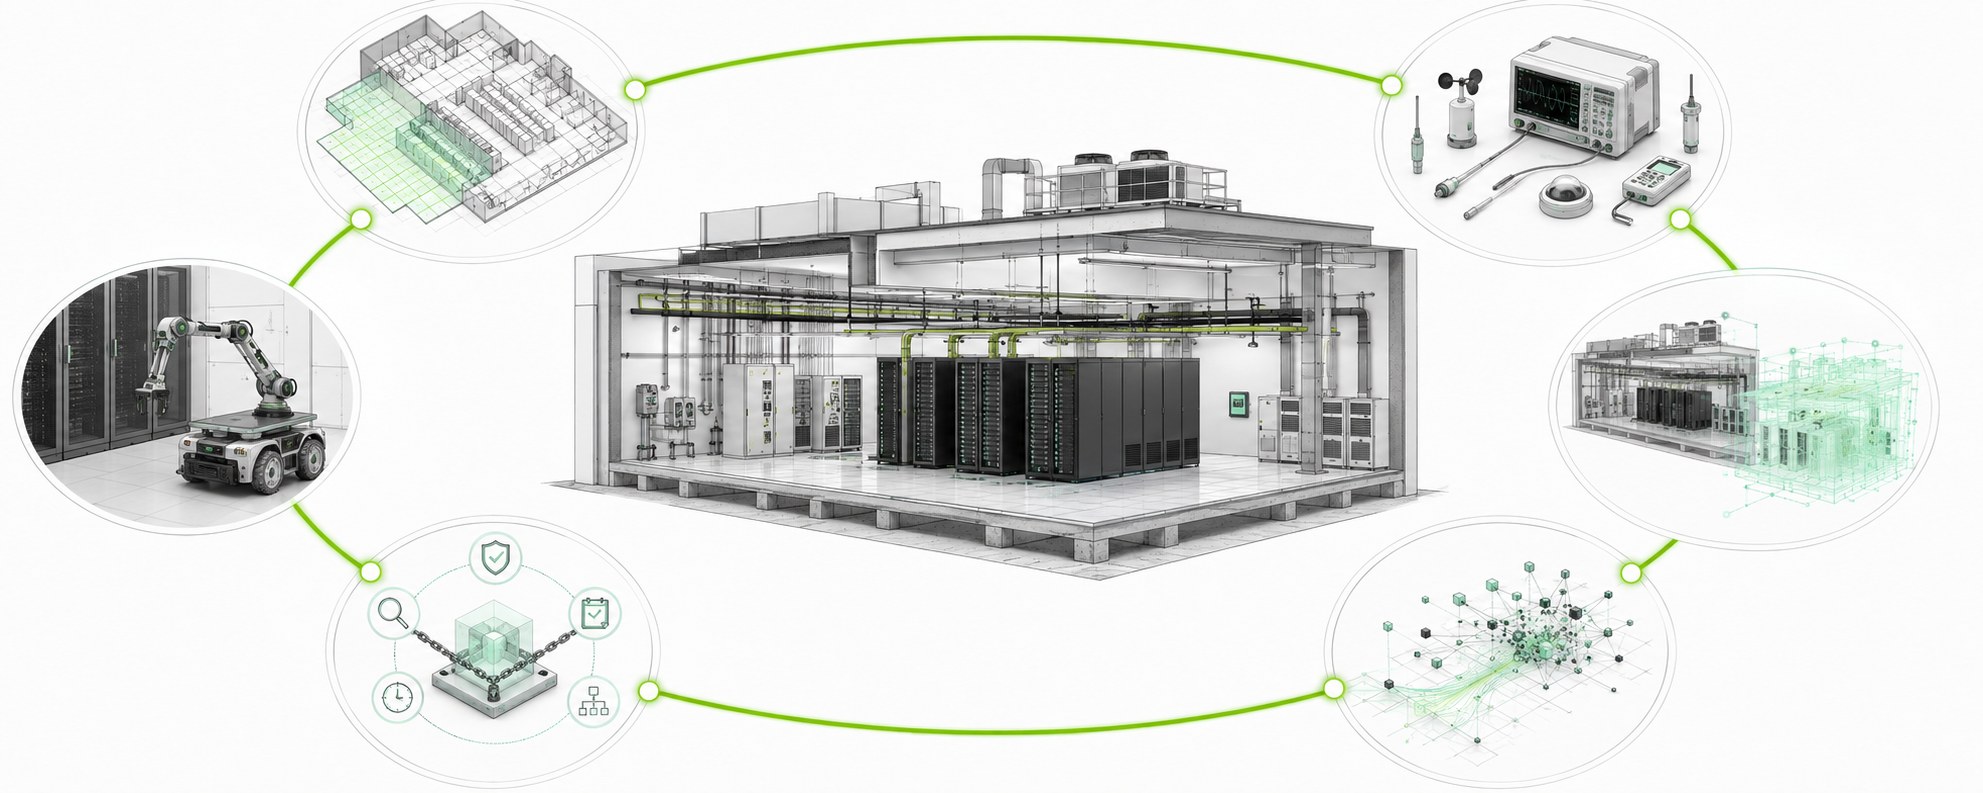
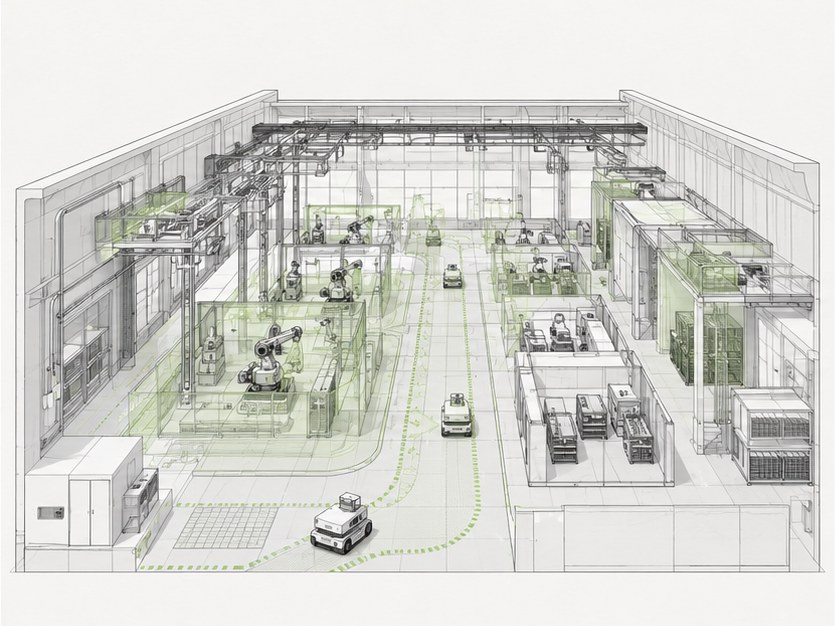
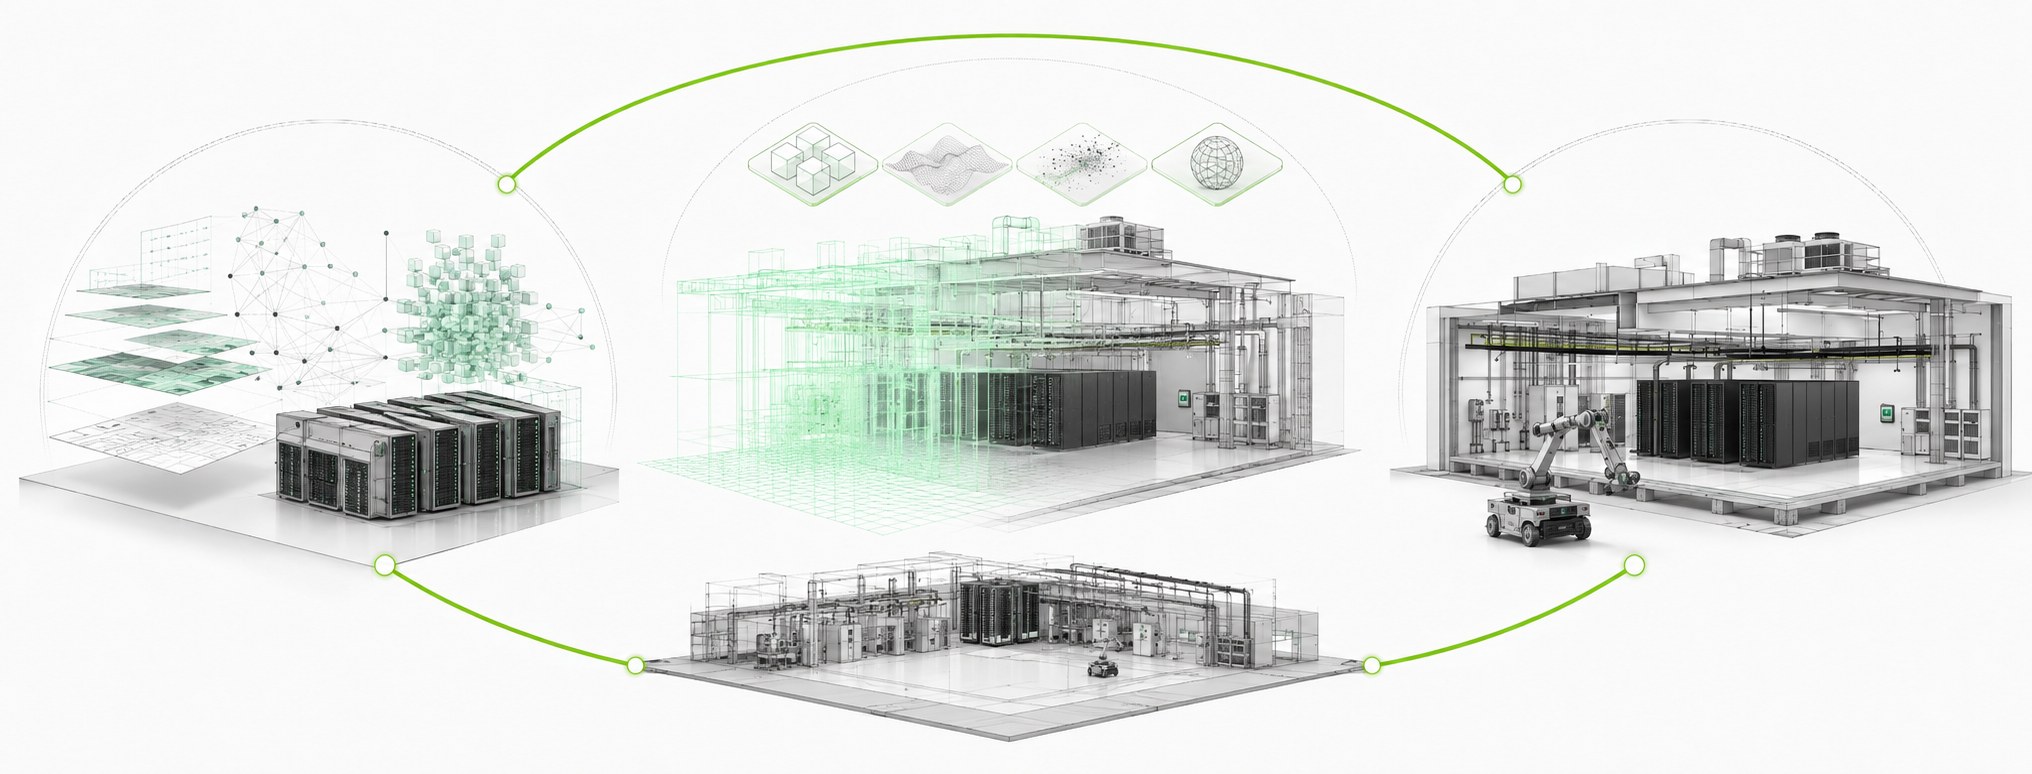
Six functions cycle through three stages: Design, Setup and Operation.
Each function's output is the precondition for the next, and the operating data
of the last flows back into the design of the next space, closing the loop.
설계(Design), 설치(Setup), 운용(Operation)의 세 단계를 6개 기능이 순환합니다.
앞 기능의 산출물이 다음 기능의 성립 조건이 되고,
마지막 기능의 가동 데이터는 다음 공간의 설계로 환류되어 루프가 완결됩니다.
Design
SIM (Plan)(계획)
Working software작동 중인 소프트웨어
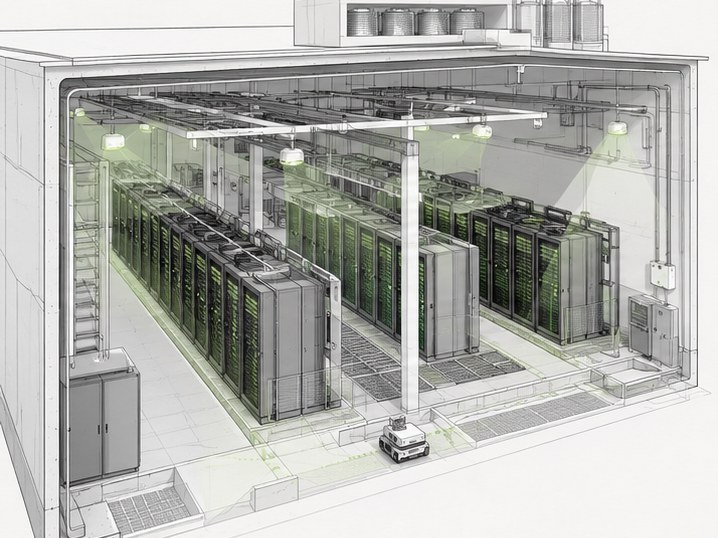
Generates layouts and evaluates capacity, feasibility and cost. What sets it apart from existing tools is that it generates the data-collection design alongside: measurement points and robot pathways. The output is exported as OpenUSD and carried straight into the twin. This is Design-for-Data.
배치안을 생성하고 수용량, 타당성, 비용을 검토합니다. 계측점 배치와 로봇 동선, 곧 데이터
수집 설계를 함께 생성한다는 점이 기존 도구와 다릅니다. 산출물은 OpenUSD로 출력해 트윈에
그대로 연계합니다.
이것이 Design-for-Data입니다.
Setup
LAB (Measure)(실측)
In development개발 중
Quantifies what a space actually does under maximum load. The GPU cluster
itself becomes the controllable load source, instrumented through DCGM telemetry. These
measured values are the reference for Real-to-Sim calibration.
최대 부하에서 공간이 실제로 어떻게 거동하는지를 수치화합니다. GPU 클러스터
자체가 제어 가능한 부하원이 되며, DCGM 텔레메트리로 계측합니다. 이 실측값이 Real-to-Sim
보정의 기준값이 됩니다.
Setup → Operation
TWIN (Sync)(동기화)
Demo built, in development데모 구축, 개발 중
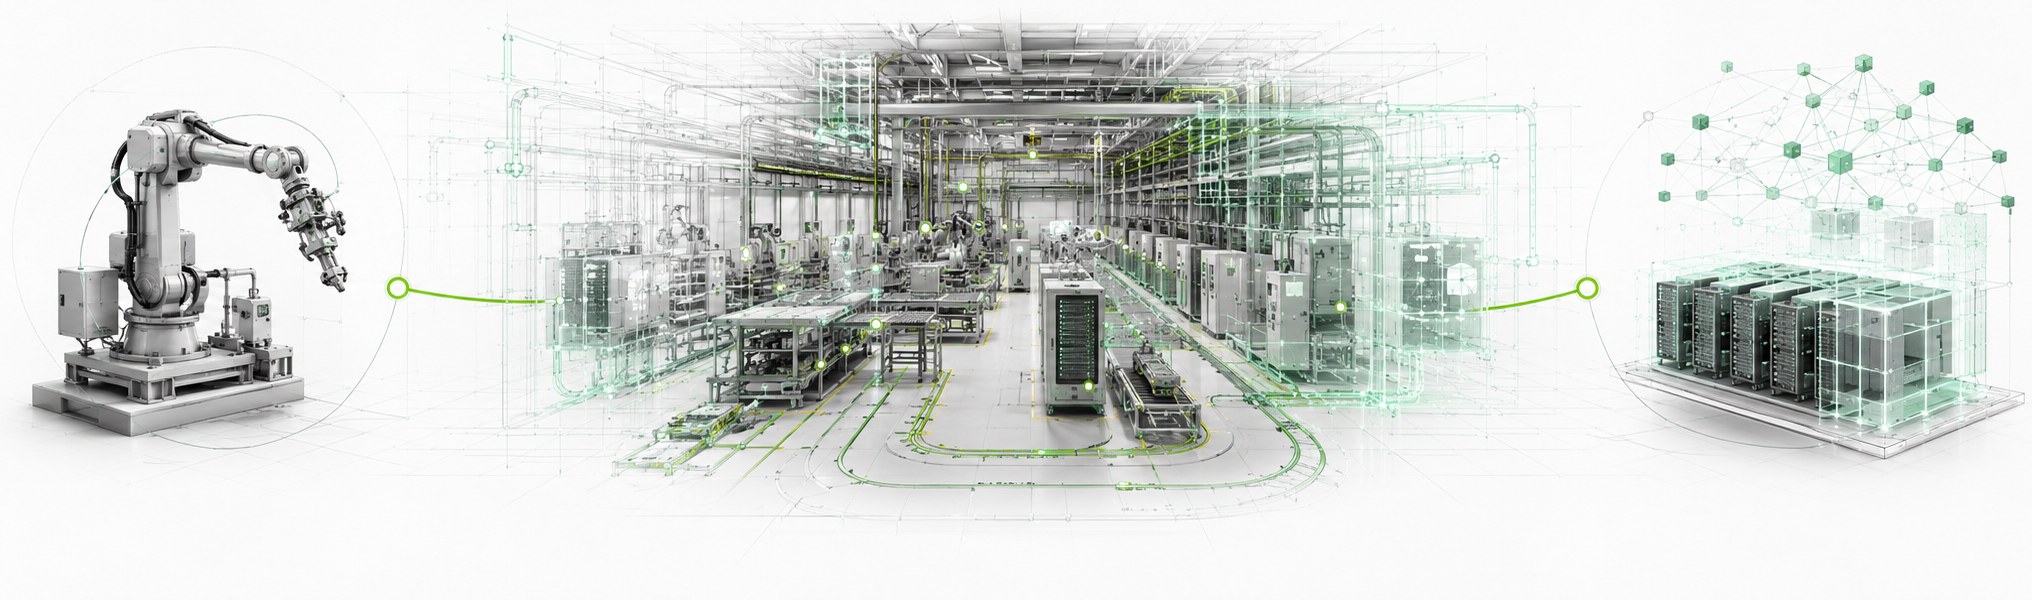
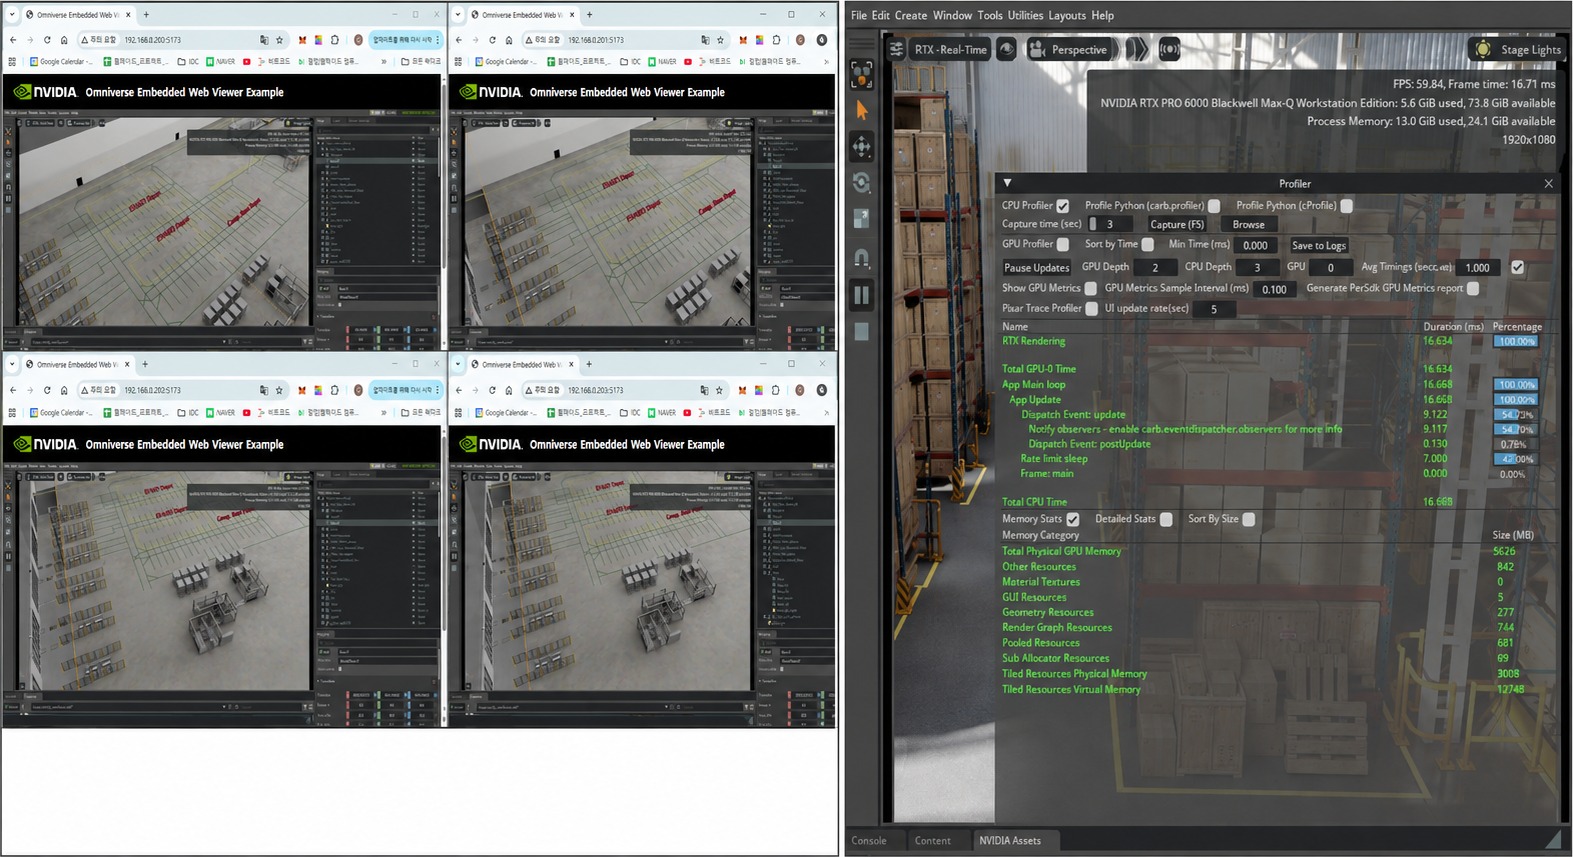
A continuously synchronized digital twin on Omniverse DSX Blueprint, built on
measured reference values rather than assumptions. This twin becomes the training
environment for robot policies.
Omniverse DSX Blueprint 기반의 상시 동기화 디지털 트윈입니다. 가정값이 아니라
실측 기준값을 토대로 구성합니다. 이 트윈이 로봇 정책의 훈련 환경이 됩니다.
Operation
VERIFY (Attribute)(귀속)
In development, patent filed개발 중, 특허 출원 완료
Attributes the cause of an operating incident and seals the evidence, so that what happened is recorded as proof rather than as a claim.
운영 중 발생한 사건의 원인을 귀속하고 증거를 봉인합니다. 발생 경위를 주장이
아니라 증명으로 남깁니다.
Operation
DATA (Capitalize)(자산화)
Architecture fixed, patent filed아키텍처 확정, 특허 출원 완료
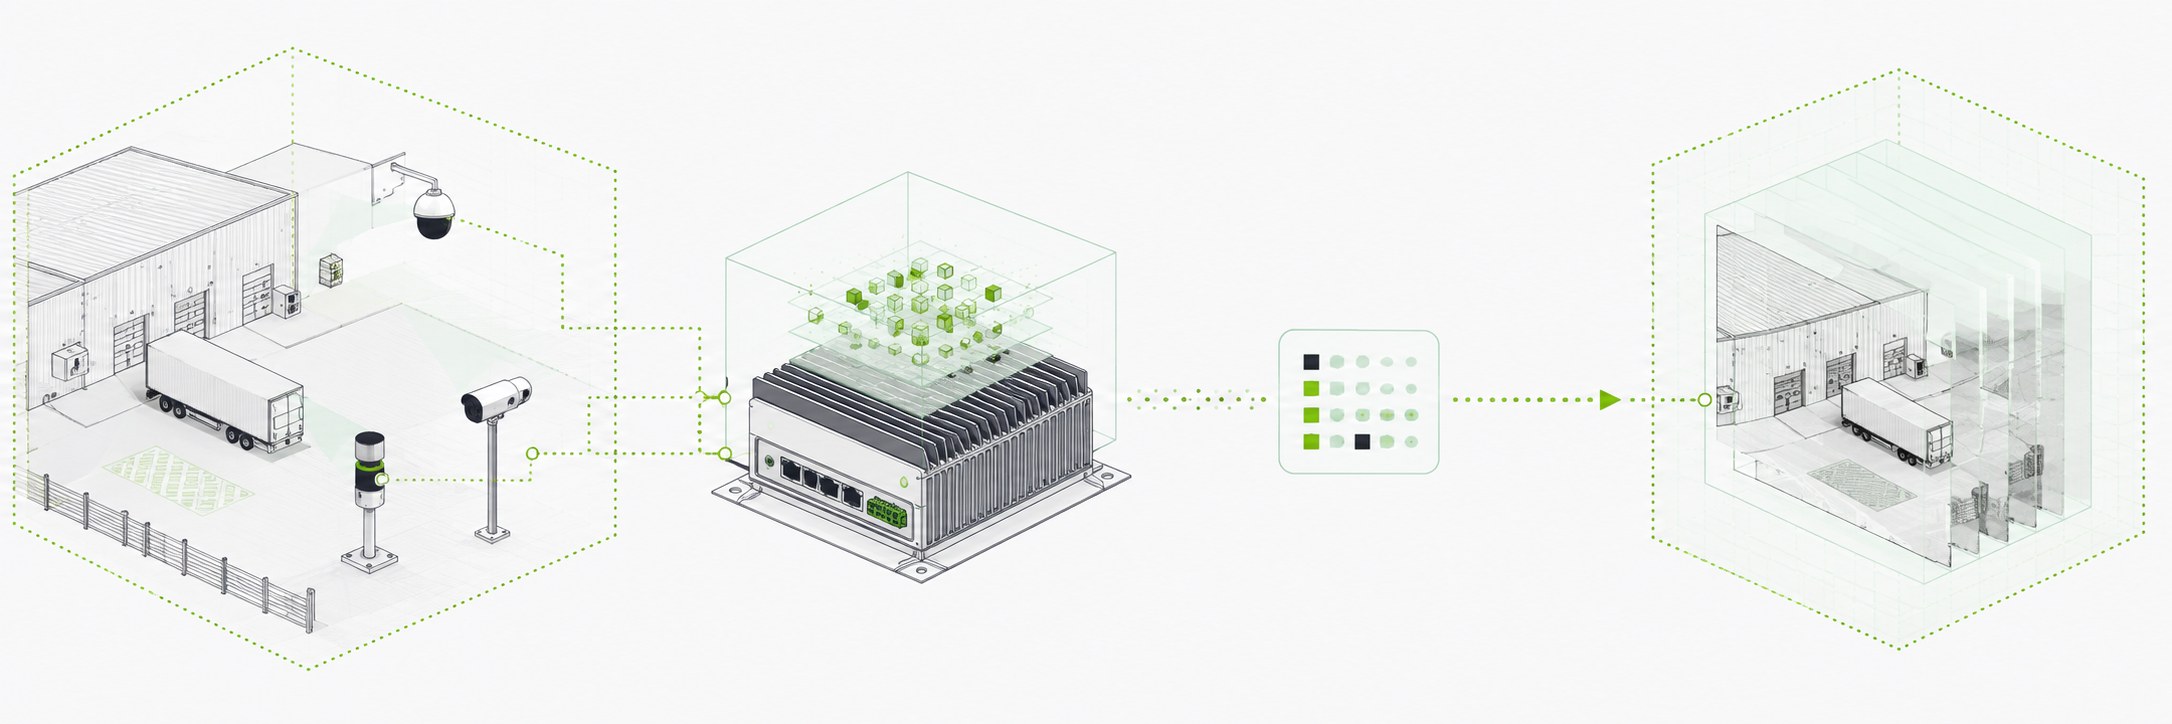
Telemetry from the running infrastructure labels whether a robot task
succeeded, with no human annotation and no simulation. Only verified records enter the
dataset, and de-identification happens at the edge, so raw footage never leaves the site.
가동 중인 인프라의 계측값으로 로봇 작업의 성공 여부를 판정합니다. 사람이 라벨을
붙이거나 시뮬레이션에 의존하지 않습니다. 검증을 통과한 기록만 자산으로 편입하며, 비식별
처리는 현장 엣지에서 수행합니다.
Operation
ROBOT (Execute)(수행)
Roadmap로드맵
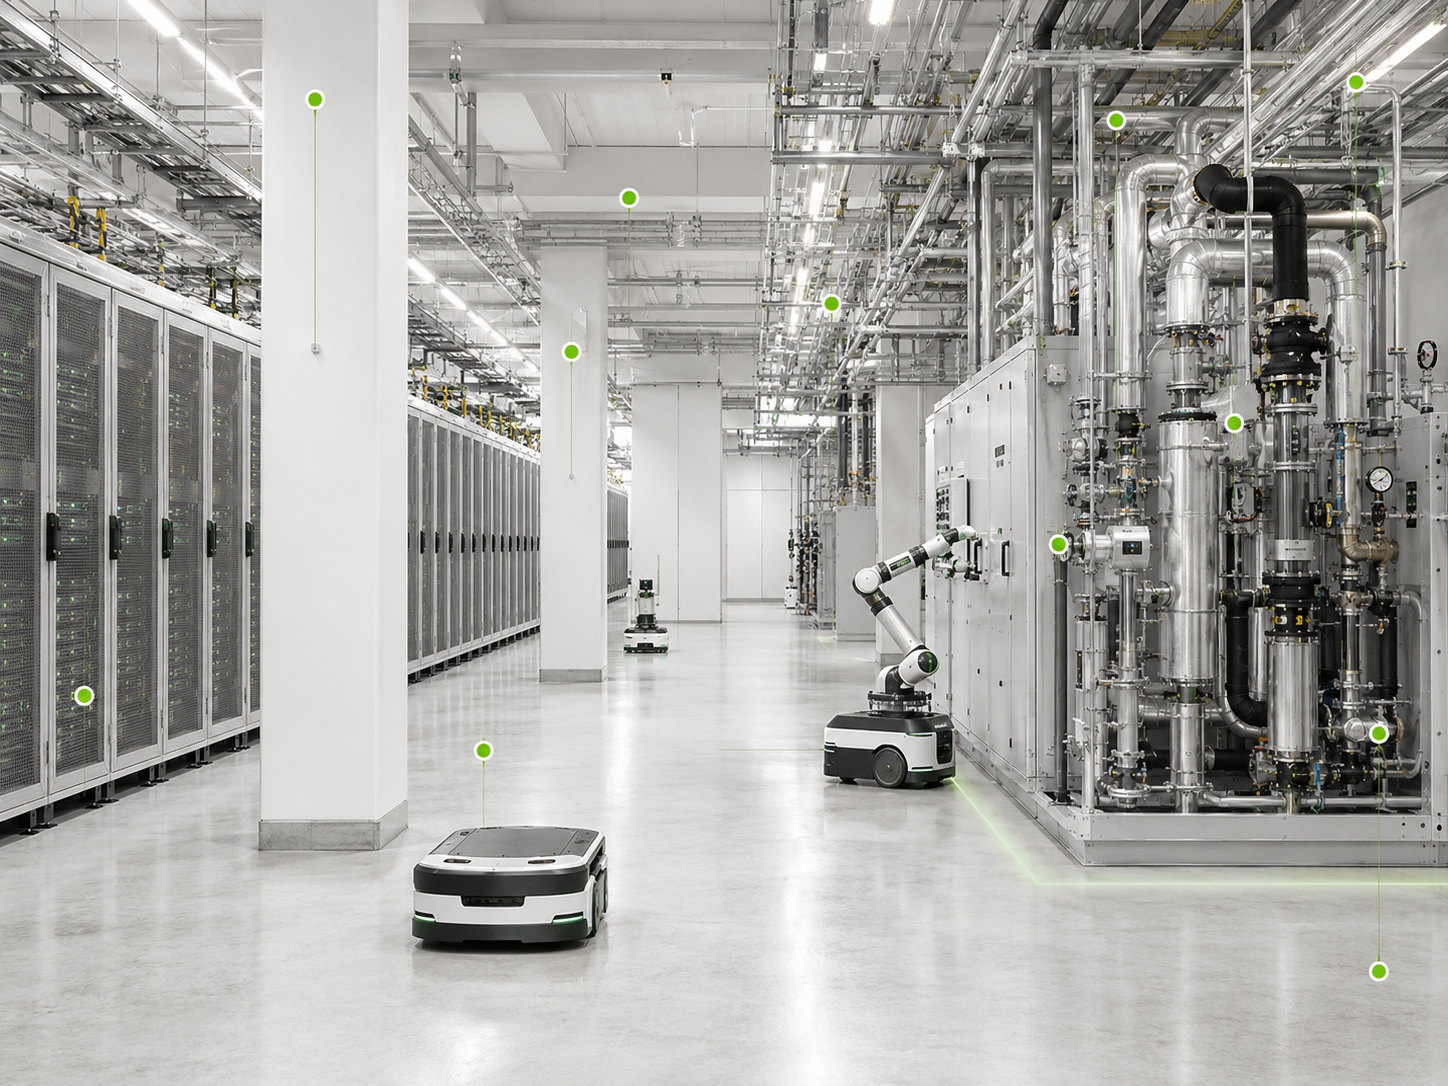
Robots trained on verified data carry out operation and maintenance of the
space, and their operating data feeds back into the design of the next one. We do not build
the robots; the bodies come from the ecosystem.
검증 데이터로 학습한 로봇이 공간의 운용과 유지보수를 수행하고, 그 가동
데이터는 다음 공간의 설계로 환류됩니다. 로봇 본체는 직접 만들지 않고 생태계에서
조달합니다.